
Insights
A Two-Actuator Soft Robot Swims in 3D: The Component Lesson Is Simplicity
ROBOTICS & SMART HARDWARE
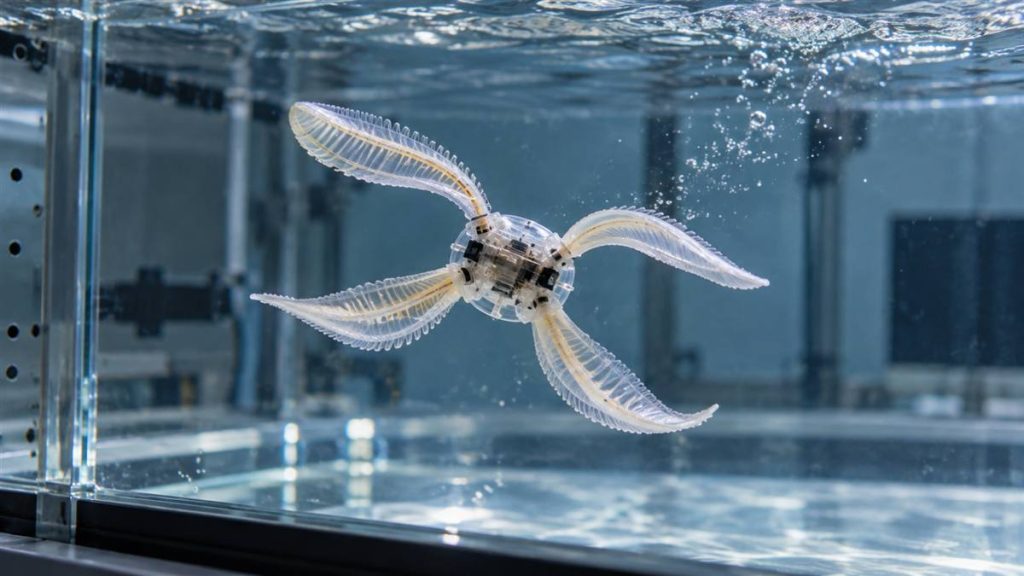
A new aquatic robot shows how structural design can replace actuator count: two pneumatic inputs produce three swimming modes that would normally require a much more complex control architecture.
Three modes from two inputs
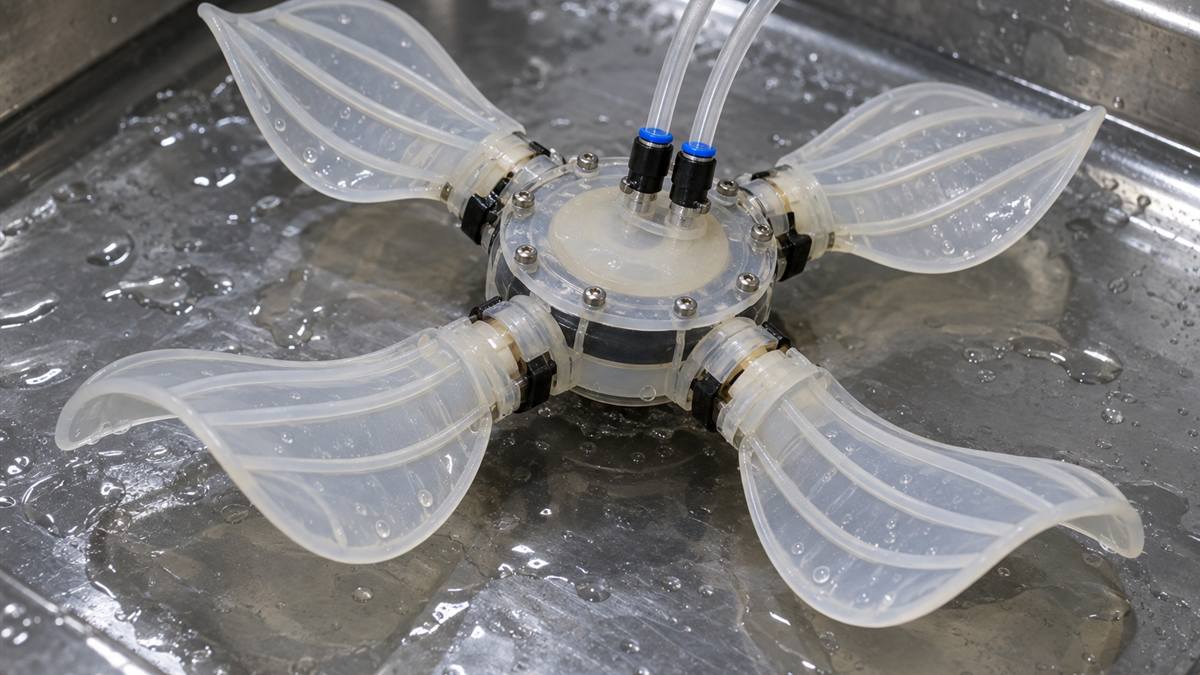
North Carolina State University reported the research on 7 October 2026. The robot has four elastic, monostable wings around a central disk. Driving both actuators produces a jellyfish-like mode for rising, descending and hovering; driving one side produces fish-like forward or backward motion; alternating the inputs produces rotor-like reorientation.
The published results report a maximum speed of 1.64 body lengths per second and peak rotation of 90° per second. The researchers demonstrated camera-based underwater exploration and cooperative object lifting, while identifying a fully wireless version as a future step.
What buyers should take from the research
The immediate opportunity is not a catalogue robot ready for mass purchasing. The useful sourcing principle is mechanical intelligence: if geometry and material elasticity perform part of the control task, the system can reduce motors, cables, penetrations and failure points.
For custom camera robots and intelligent hardware, TUOLAN TRADE’s custom sourcing process starts with the operating environment and validation target. Underwater hardware needs particular attention to elastomer fatigue, actuator repeatability, adhesive compatibility, pressure cycling, optical-window clarity and leak testing.
Prototype RFQ checklist
- Define depth, water type, mission time and permissible tethering.
- Specify payload mass, camera field of view and acceptable vibration.
- Request cycle-life data for flexible wings and pneumatic interfaces.
- Separate research performance from production-ready reliability claims.
Need a sourcing-ready specification?
TUOLAN TRADE can help translate performance targets into an RFQ, supplier comparison and sample-validation plan.
Primary source: NC State University, 7 October 2026; Science Advances DOI 10.1126/sciadv.aeg9211. Facts and dates checked on 8 October 2026.
Edited and analysed by TUOLAN TRADE.